One Maker Spent a Year Fighting Plastic Failures and Aluminum Tolerances to Build a Robot Joint That Can Actually Walk
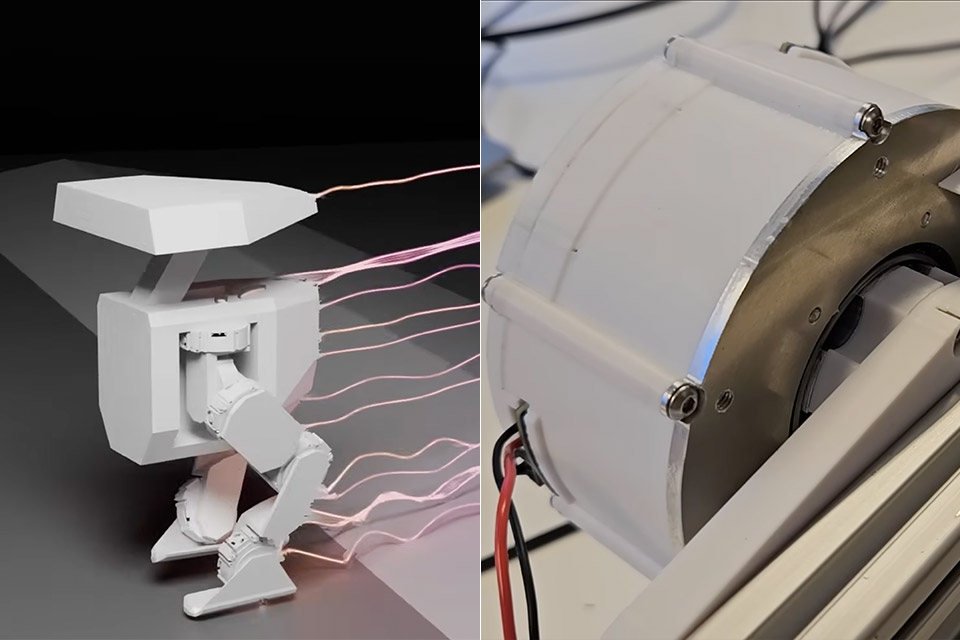
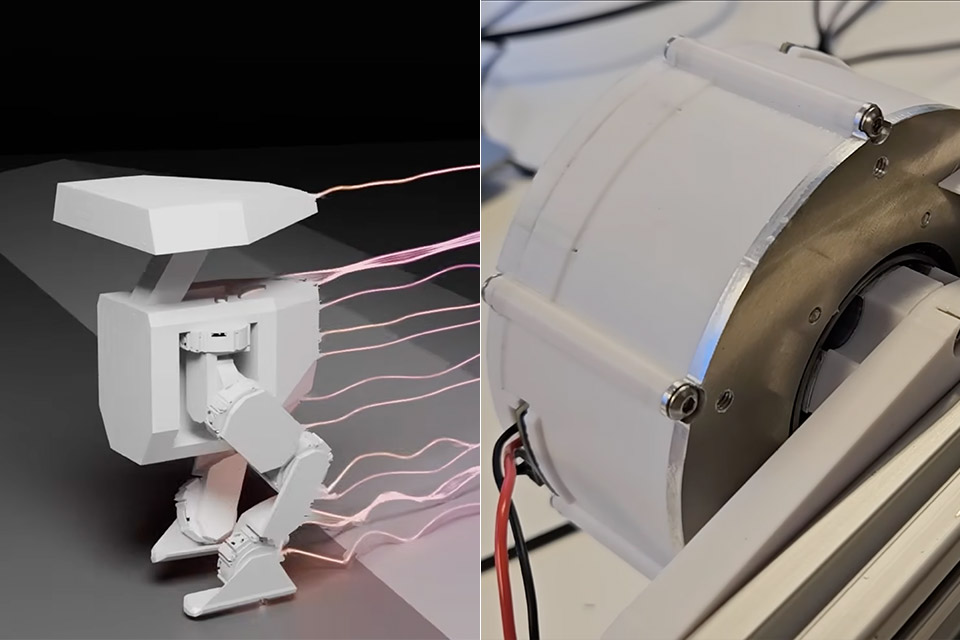
Robots that walk face a stubborn problem right at the joints. Biological legs spread force along muscles that run the length of a limb. Most mechanical versions must pack everything into a tight space at the knee or hip. That means the actuator needs to stay compact and light while still delivering serious torque and staying backdrivable so the leg can absorb shocks instead of fighting them.
Food for Robots set out to solve the difficulty of creating a bipedal machine inspired by Disney’s BDX Droids. The goal was to fit around 20 newton-metres of continuous torque into a container small enough to crush at the joint. The first time around, the crew came close with a nearly fully 3D printed work that featured a novel double-folded capstan motor that used rope to increase force multiplication. Initially, it functioned fine up to approximately 10 Nm, but after that, the printed pulleys began to split under stress, the rope slipped whenever the ratio became too large, and the rotor shaft just couldn’t handle it. When it came to a whole robot that could have to bear its weight on one leg, they fell well short at 10 newton meters.
Sale

LEGO Star Wars R2-D2 Building Toy Set – Play or Display Star Wars Toy for Boys & Girls, Ages 10+ – Gift…
- LEGO R2-D2 Star Wars buildable toy figure – Create a playful centerpiece featuring this detailed brick-built LEGO figure of one of the most beloved…
- Buildable fantasy toy display model with playful details – R2-D2 has a 360-degree rotating head, detachable third leg for mobility, an attachable…
- An R2-D2 LEGO droid figure and a LEGO Star Wars minifigure – The main buildable toy model comes with an R2-D2 LEGO figure, plus a LEGO Star Wars…
A complete rethink ensued, with the first step being to replace plastic with metal, and what a difference it made. Gears and structural components were CNC cut from 7075 aluminum, which is far stronger than the more common 6061 alloy. They removed the capstan and replaced it with a planetary gearbox located in the open center of the motor stator. The sun gear, ring gear, and all of the planet gears were machined from 3mm layer stacks, allowing the small machine to still produce strong parts that could withstand heavy loads. The planets’ carrier proved too difficult for the local CNC to handle, so it was outsourced for metal 3D printing instead. The rotor was outfitted with 21 pole pairs of permanent magnets, as well as a tiny diametrically magnetized magnet on the rear face, to allow the controller to read the absolute position without relying on an external encoder.
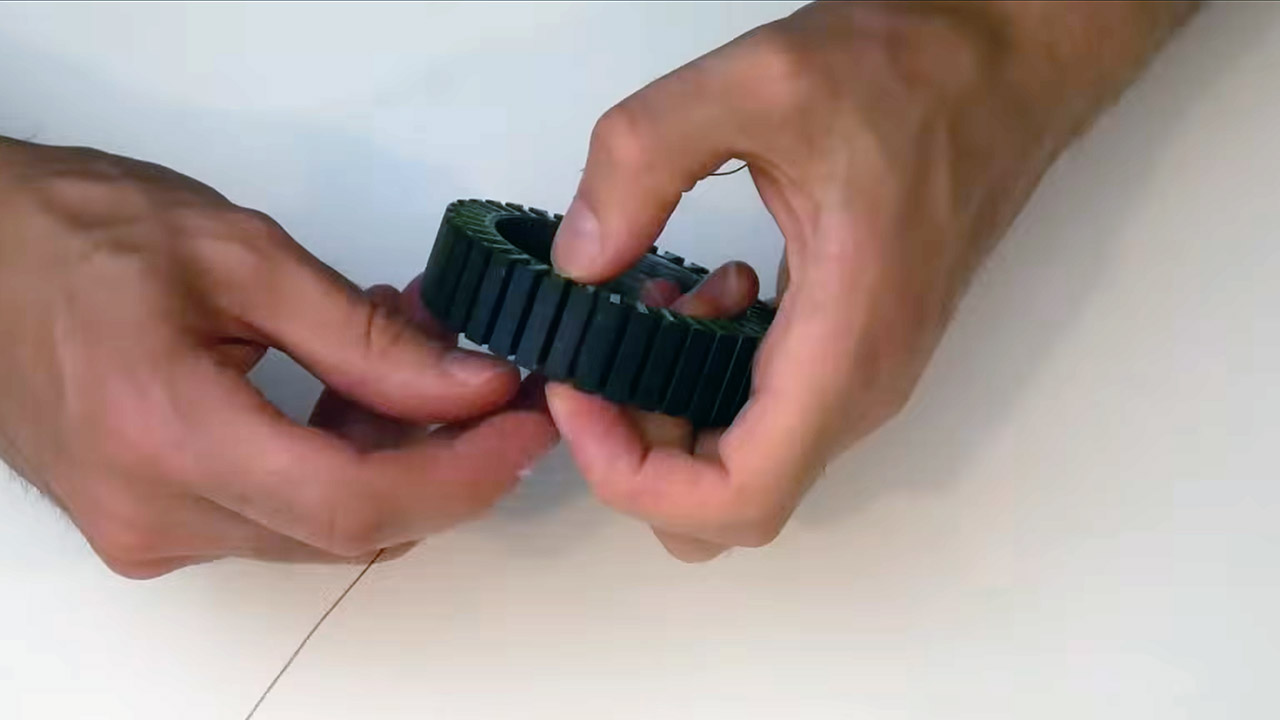
The stator itself had a growth surge, nearly doubling in length in an attempt to generate more torque without increasing the motor diameter significantly. Three-phase windings were inserted into the slots. They started with fewer turns and eventually tried 36. A custom control board based on an ESP32-S3 and a DRV8302 driver board, running the SimpleFOC library and field-oriented control, kept everything running smoothly; it was the same board as the first attempt, with a few tweaks. A small fan moves air across the driver, thru the rotor, across the gearbox, and out the other side thru several cleverly placed vents.
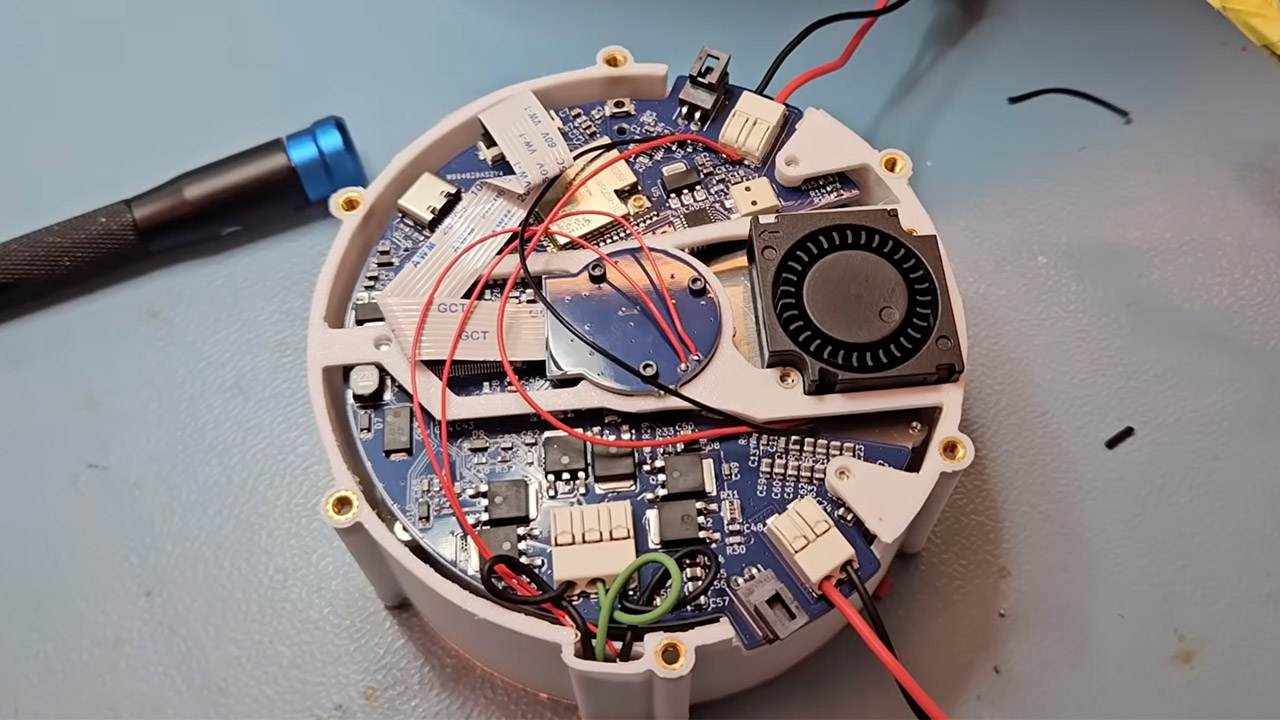
As always, the first time an assembly is put together, you encounter the regular shop realities. The tolerances just didn’t stack up. A carrier that appeared excellent in CAD was only a fraction off after hand-finishing, resulting in bearing wobbling. The gears measured perfectly, but refused to mesh until they were slightly adjusted. Every minor mismatch necessitated disassembling the entire structure and reassembling it, as is customary. The finished unit measured 102mm across, 48mm thick, and weighed 900 grams. It appears to be a little chunkier than its printed predecessor, but it feels really durable.
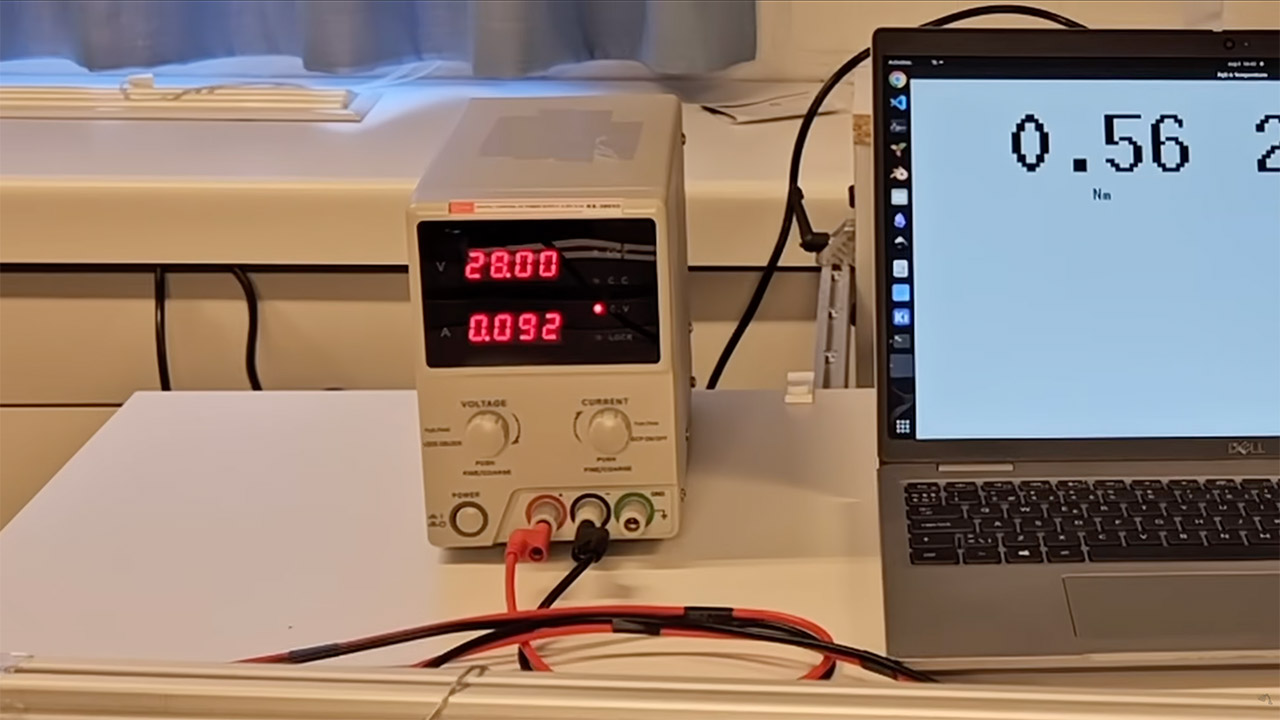
The first torque tests were a significant letdown, as even with the stator thickened, the actuator failed to generate more than 10 Nm at the same power levels that had previously functioned perfectly. Upgrading the coil to increase the number of turns was expected to provide us more force, but it had the opposite effect, as the resistance in the circuit increased and the current decreased while the input power stayed same. Copper’s losses scale with the square of the current, hence torque does not rise linearly with electrical power. To make matters worse, the driver functions more like a buck converter, just trading voltage for current within the windings. So, when he increased the supply voltage to 28 V while also tweaking the current restrictions in the control software, he was able to push output above 18 Nm and on to our objective of 20 Nm with only 100 W of losses. The good news is that the mechanical pieces absorbed the punishment without splitting or slipping, as the earlier plastic version did when pressed too hard.
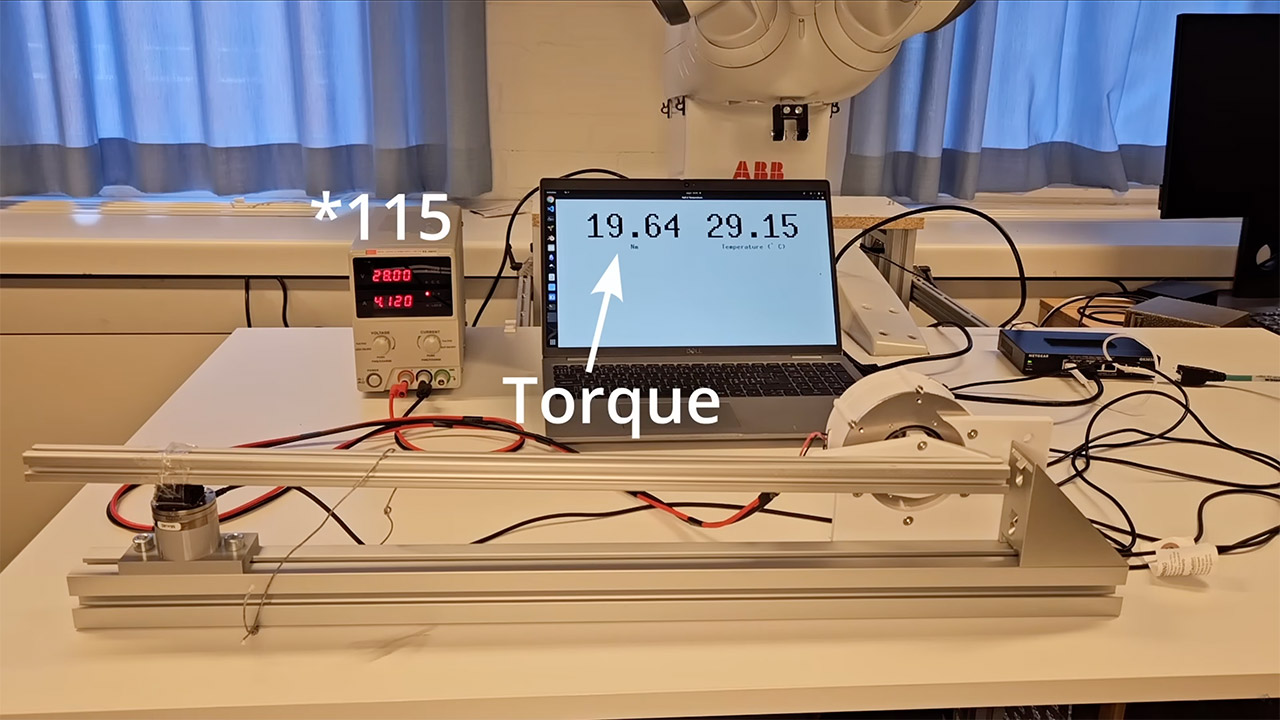
The ultimate result is an actuator that can not only sit comfortably at a robot joint, but also produce the torque he requires and give a little when he encounters an unexpected surface. It’s been a long journey, with over a year of trial and error, broken pulleys, misaligned carriers, and numerous all-nighters spent battling electrical gremlins. Food For Robots still has a whole walking machine to finish, but at least the most difficult piece of hardware is now sitting on the workbench, waiting for the next step.
[Source]
One Maker Spent a Year Fighting Plastic Failures and Aluminum Tolerances to Build a Robot Joint That Can Actually Walk
#Maker #Spent #Year #Fighting #Plastic #Failures #Aluminum #Tolerances #Build #Robot #Joint #Walk